01 / 06
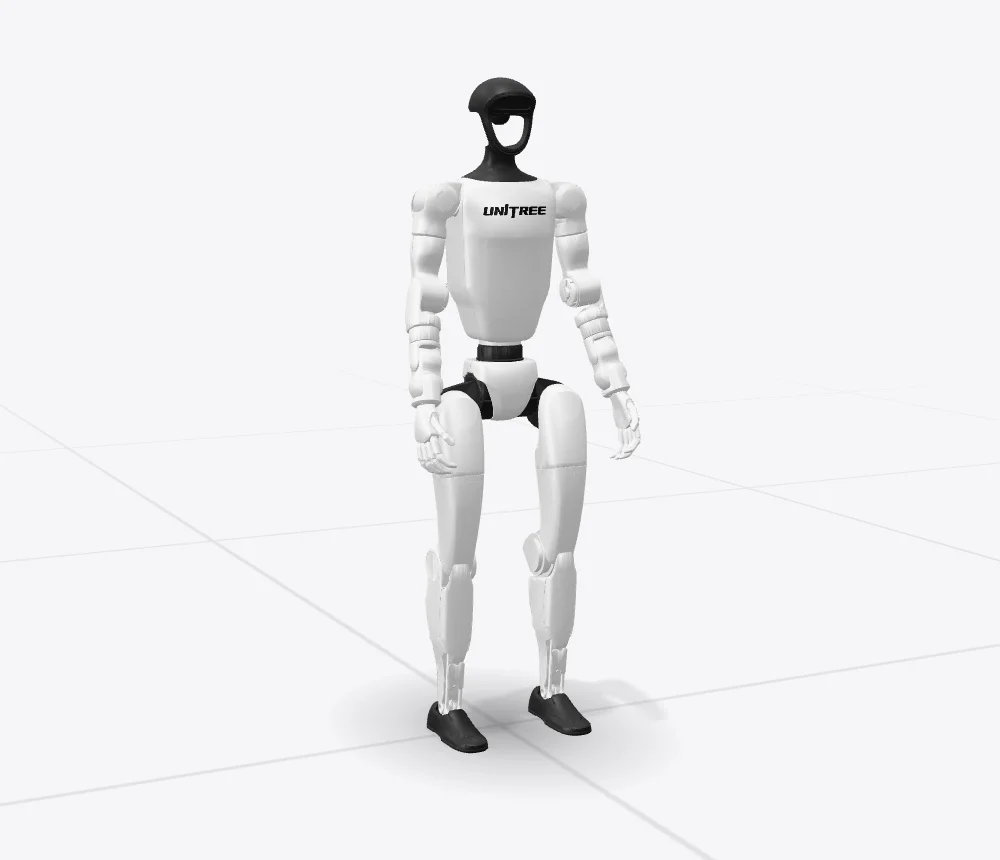
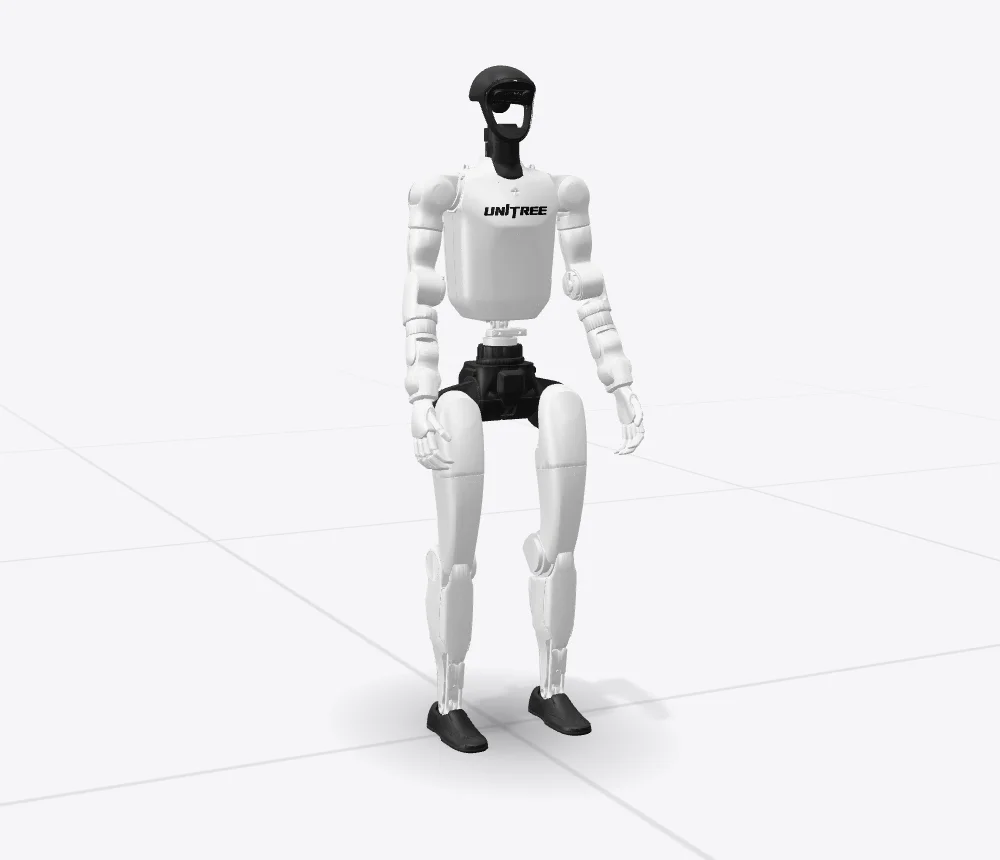
Unitree G1
Body, end effector and cameras to be confirmed.
- Expected Maximum Monthly Capacity
- 4,200 h / month
- Data in stock
- 600 h
Human demonstrations on humanoid, dual-arm and dexterous-hand robots, collected at real stores, homes, labs and pharmacies. Open complete recordings here, then explore the tasks or datasets that fit your evaluation.
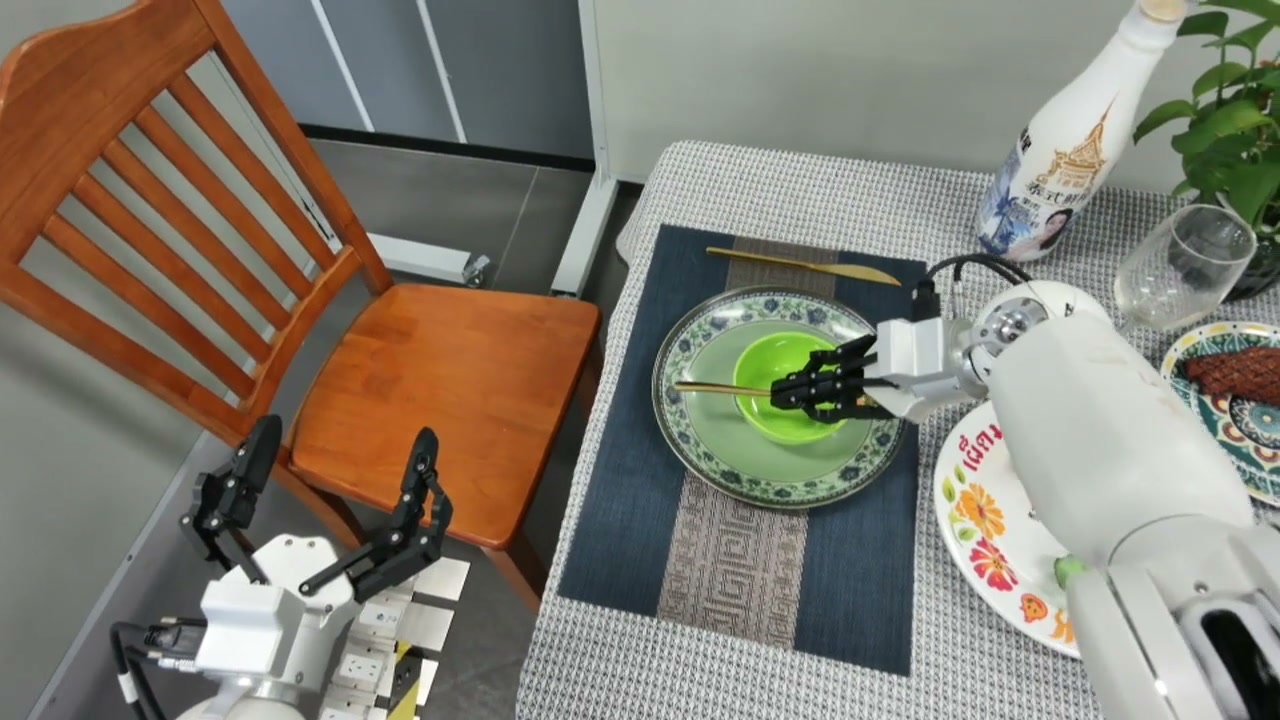
Compare the configurations we feature for new collection projects. Each card shows the setup details available today; follow through to published tasks or ask about the configuration.
We collect across scenarios. One task can vary by room, layout, object and lighting, so a project can cover more than one setup.
A video tour of our collection environments.
A rendered illustration of the variables a task can be specified against: room, layout, object and light. Illustration only, not collected footage.
Tidy a table: wipe, then return the cup. Adapt the room, objects, props, background and lighting.
Example task · Table tidyingPreparing your scene…
One long two-handed task — pour, spill, fetch a towel, wipe, pour again. Watch the scene, then the same demonstration with per-frame object masks, per-arm action labels and task-phase context.
A long task with two hands, a spill in the demonstration, and the recovery before the task continues.
Objects outlined frame by frame, each arm's action and the object it acts on, and where the moment sits in the task: first pour, spill, fetch towel, wipe, pour again.
Below is a different set: two complete published Astribot S1 recordings, without the annotation shown here. Every camera, robot signals, files and each recording's quality checks.
Open the recordings ›Two complete published Astribot S1 recordings, opened up: synchronized camera views, robot state and actions, files and fields, timing, and per-recording quality checks.
Start with a sample, run a small pilot, adjust, then scale on the same specification.
Tell us the robot, tasks and scenes you need.
We collect a small batch on the agreed setup for you to review.
You check the data; we adjust tasks, scenes or labels.
We scale collection on the agreed specification.
Questions about data sources, consent or licensing for any dataset?
Two ways to request data. Each request is reviewed before data is shared.
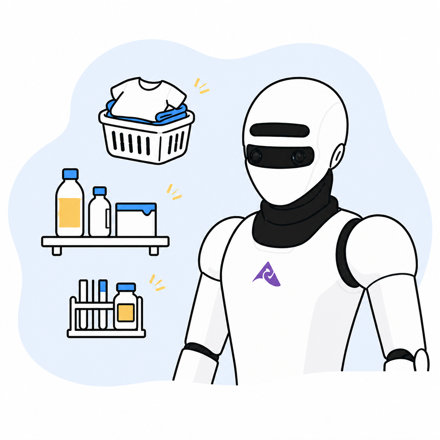
General-purpose robots need more than a larger action vocabulary. They must handle different environments, objects, and multi-step procedures. This dataset brings together 4828 real-robot recordings from Astribot S1 across 60 scenarios and 133 tasks, ranging from clothing organization, kitchen operations, and household cleaning to shelf restocking, pharmacy handling, lab sample processing, and material sorting. With 104.49 hours and 11.3 TB of complete MCAP data, it supports multi-task training, cross-scenario evaluation, and validation of industry-specific data programs. If you want to see whether the collection matches your robot and target tasks, contact us to review samples and discuss the next step.
Built around diverse Unitree G1 manipulation, this dataset spans 26 tasks across 23 home and retail scenarios, including cleaning, tidying, clothing handling, item organization, refrigerator zoning, basket-based shopping, and shelf restocking. Its 6 capture configurations cover Dex1 and BrainCo end effectors together with monocular and stereo 720p vision setups. The collection is intended to broaden the scenes, objects, and procedures available for multi-task training and to support evaluation of transfer across layouts and task sequences.
Looking for specific scenarios and tasks?
Choose scenarios ›