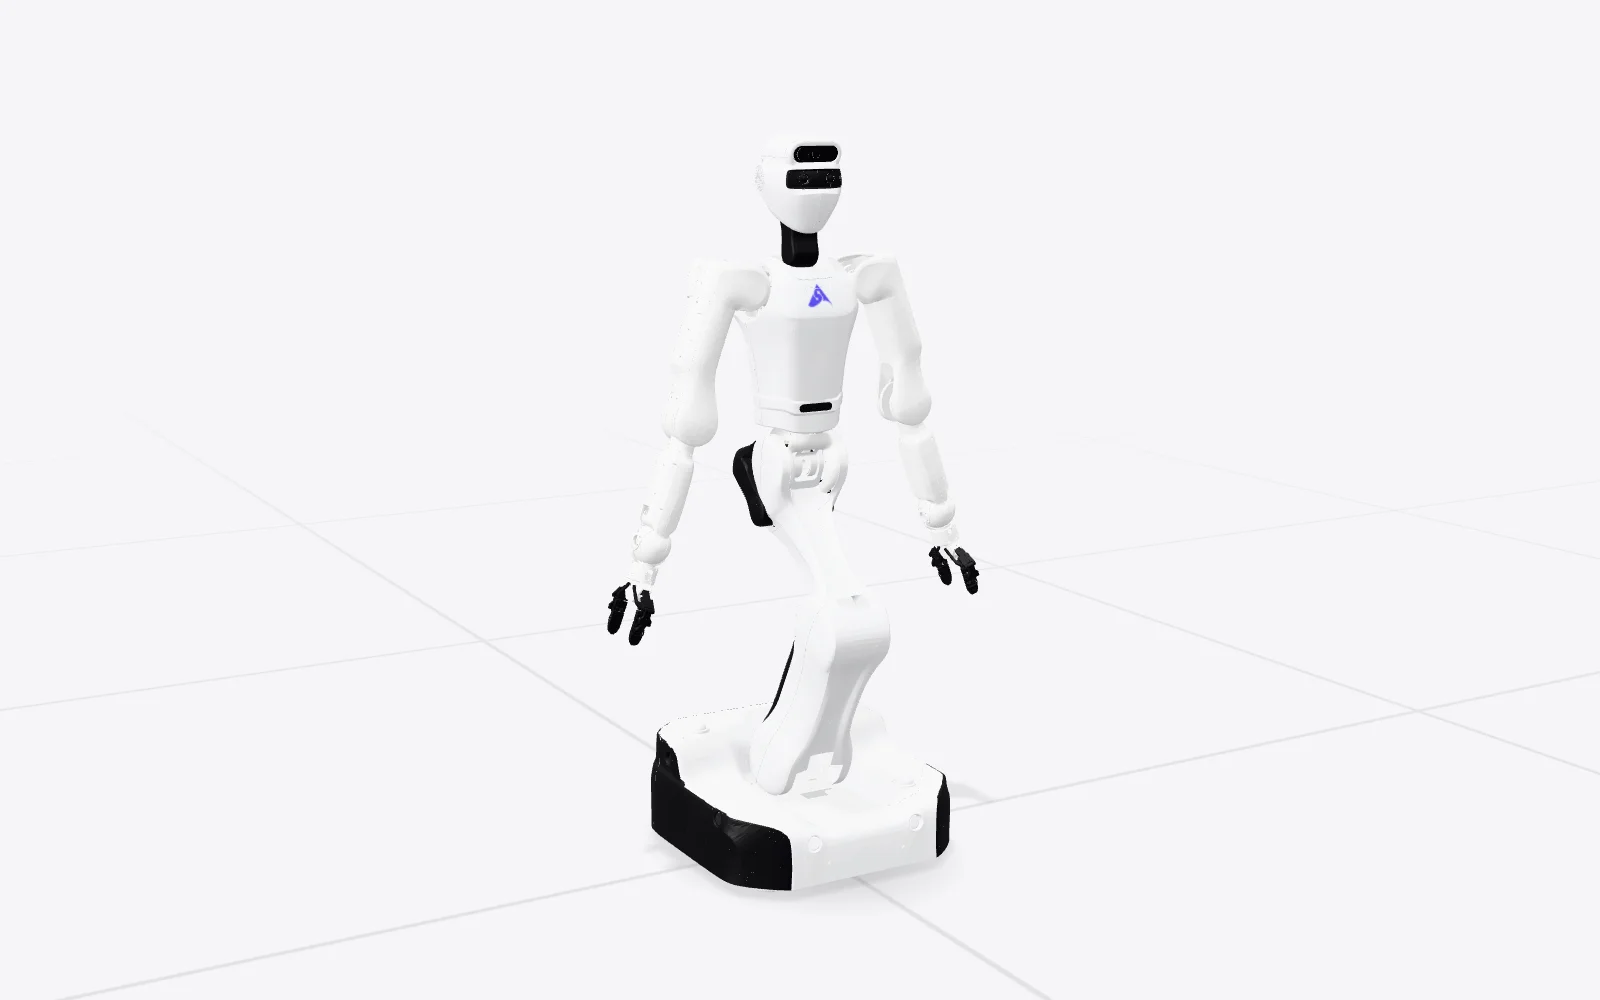
Astribot S1
- Body
- Robot platform
- End effector
- Gripper
- Cameras
- Chest RGB-D camera, 720pDual gripper RGB-D cameras, 480pHead RGB-D camera, 720pHead stereo vision camera, 720p
- Configurations
- 1
- Tasks
- 168
Specifications
S1
- Total
- 23 DOF
- Dual Arm DOF
- 7 DOF * 2
- Torso DOF
- 4 DOF * 1
- Head DOF
- 2 DOF
- Chassis DOF
- 3 DOF (Vx Vy Yaw)
Robot Performance Parameters
- Arm End-effector Rated Load (Horizontal, Continuous)
- 5 Kg
- Joint Max Velocity
- 500 °/s (Shoulder), 800 °/s (Elbow), 1200 °/s (Wrist)
- Joint Max Torque
- 200 Nm (Shoulder), 66 Nm (Elbow), 18 Nm (Wrist)
- Arm End-effector Maximum Velocity
- >10 m/s
- Arm End-effector Maximum Acceleration
- >100 m/s²
- Arm End-effector Repeatability
- ±0.1 mm
Sensor System
- Head camera
- RGB-D camera * 1; Stereo vision camera * 1 1280×720, 30 FPS, FOV: 80°×51°
- Gripper camera
- RGB-D camera * 2 640×480, 30 FPS, FOV: 78°×63°
- Chest camera
- RGB-D camera * 1 1280×720, 30 FPS, FOV: 86°×55°
- Chassis LiDAR
- LiDAR * 2
Others
- Battery
- 1000 Wh
- Chassis Velocity
- 1.67 m/s (Unlockable to higher velocity)
- Driving method
- Cable-driven & Motor-driven
- Data collection method
- VR whole body collection