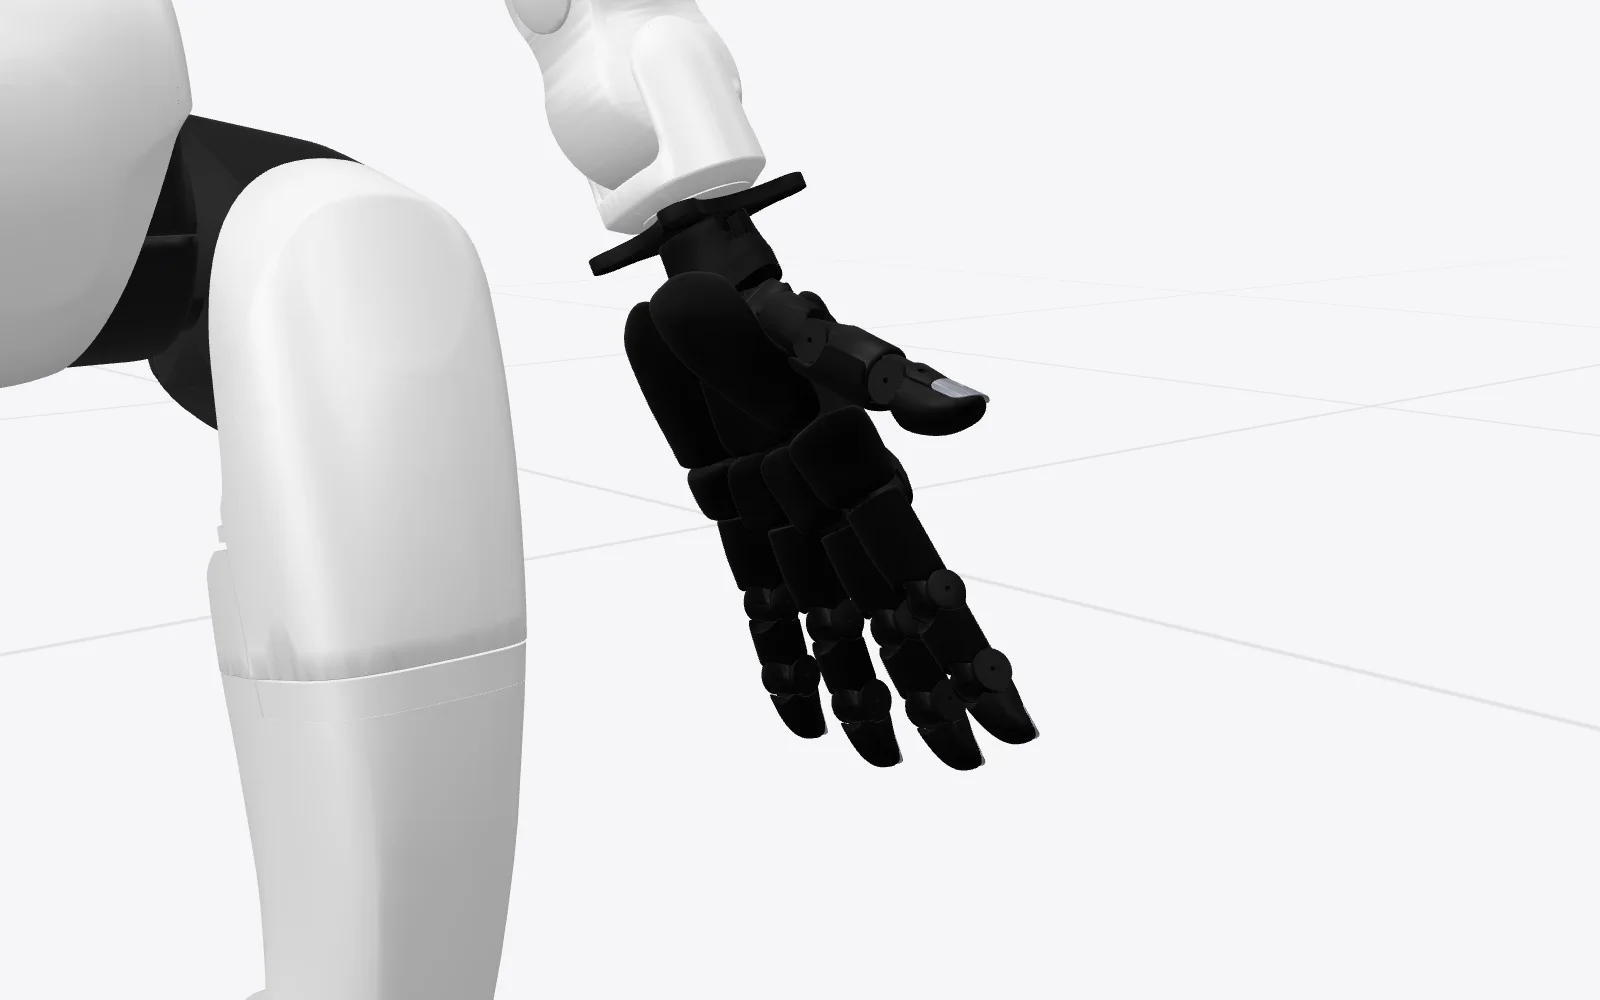
Wuji Hand 2
- Type
- Dexterous hand
Specifications
Degrees of Freedom
- Active degrees of freedom
- 20 (4 per finger)
- Joint count
- 20 (4 per finger)
Mechanical Structure
- Grasp configuration
- Full opposition, with lateral abduction supported
- Kinematic configuration
- Serial direct-drive rotary joints, no nonlinear kinematic coupling
- Minimum grasp diameter
- 0 mm
- Weight (with soft pad and output cable, excluding adapter mount and adapter flange)
- 800 g
- Dimensions
- 180 mm × 80 mm × 40 mm
Joint / Actuator System
- Drive type
- Back-drivable direct-drive rotary joints
Control
- Control algorithm
- FOC vector control
- Control frequency
- 1000 Hz × 20 axes
- Control mode
- MIT force-position hybrid control
Interfaces
- Communication interface
- RJ45, 100BASE-TX
Power
- Operating voltage
- 12 V DC
- Power adapter
- 12 V 20 A (included)
Perception / Sensors
- Prototype variant
- Non-tactile
Joint Motion Range
- Thumb CMC flexion (thumb_cmc_flex)
- -68° ~ 74°
- Thumb CMC abduction (thumb_cmc_abd)
- -85° ~ 40°
- Thumb MCP flexion/extension
- -60° ~ 90°
- Thumb IP flexion/extension
- -60° ~ 90°
- Index / middle / ring / little MCP flexion/extension
- -60° ~ 90°
- Index / middle / ring / little MCP abduction
- -40° ~ 40°
- Index / middle / ring / little PIP flexion/extension
- -60° ~ 120°
- Index / middle / ring / little DIP flexion/extension
- -60° ~ 90°