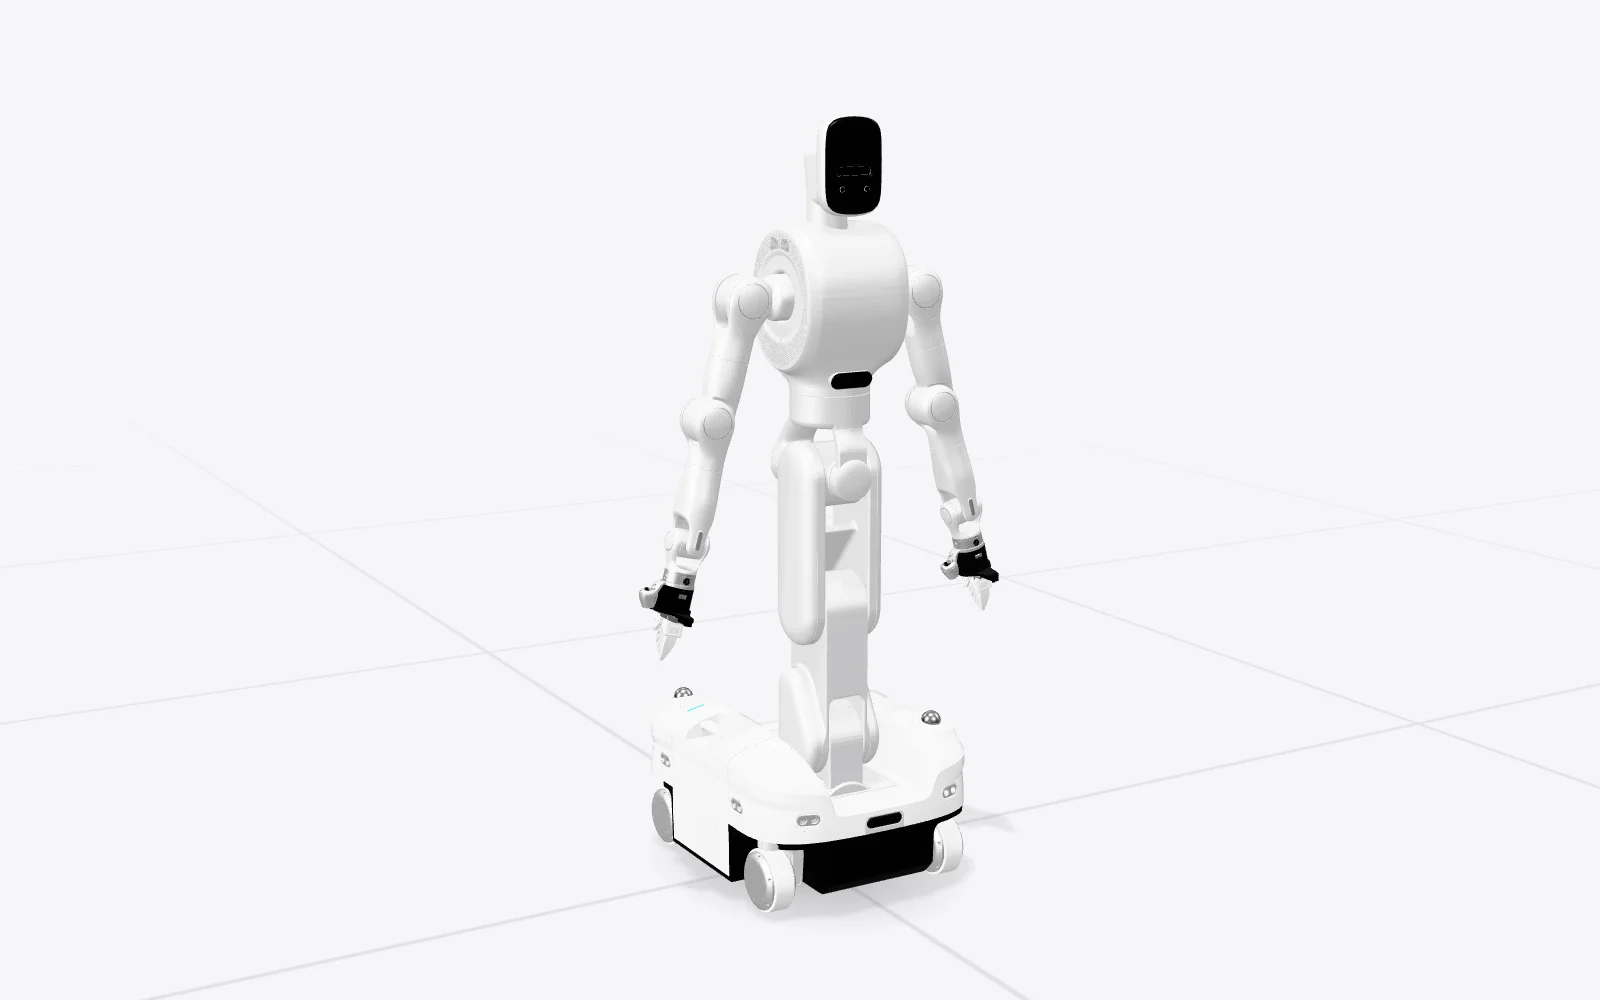
Tianji Gento Luna
- Body
- Robot platform
Specifications
Mechanical Structure
- Height (fully extended)
- 1700 mm
- Minimum height (folded)
- 790 mm
Degrees of freedom
- Total degrees of freedom
- 26 (excluding dexterous hands)
- Degrees of freedom per arm
- 7 (force-controlled humanoid arm)
- Waist and legs degrees of freedom
- 6 (force-controlled joints)
Arm
- Rated payload per arm
- 6 kg
Motion Control
- Force control
- Standard whole-body force control; compliant impedance control
- Autonomous navigation
- Real-time obstacle avoidance and autonomous path planning
- Stability control
- Active anti-tipping; real-time stability margin calculation, motion constraints and posture adjustment
Mobility
- Mobile chassis
- Omnidirectional mobile chassis; in-place rotation and omnidirectional translation
Compute
- Computing platform
- NVIDIA Jetson Orin AGX 64GB
- Computing power
- Up to 275 TOPS
Power / Battery
- Battery pack
- 48 V 34.4 Ah lithium iron phosphate
- Continuous operation
- 4–8 hours
- Charging / battery replacement
- Manual charging, automatic charging, quick battery swap
Perception / Sensors
- Navigation sensors
- 3D LiDAR and ultrasonic radar fusion
- Mapping precision
- Centimeter-level
- Interaction system
- Expressive lighting system with visual recognition
Interfaces
- Software development support
- ROS 2; SDK and secondary development APIs