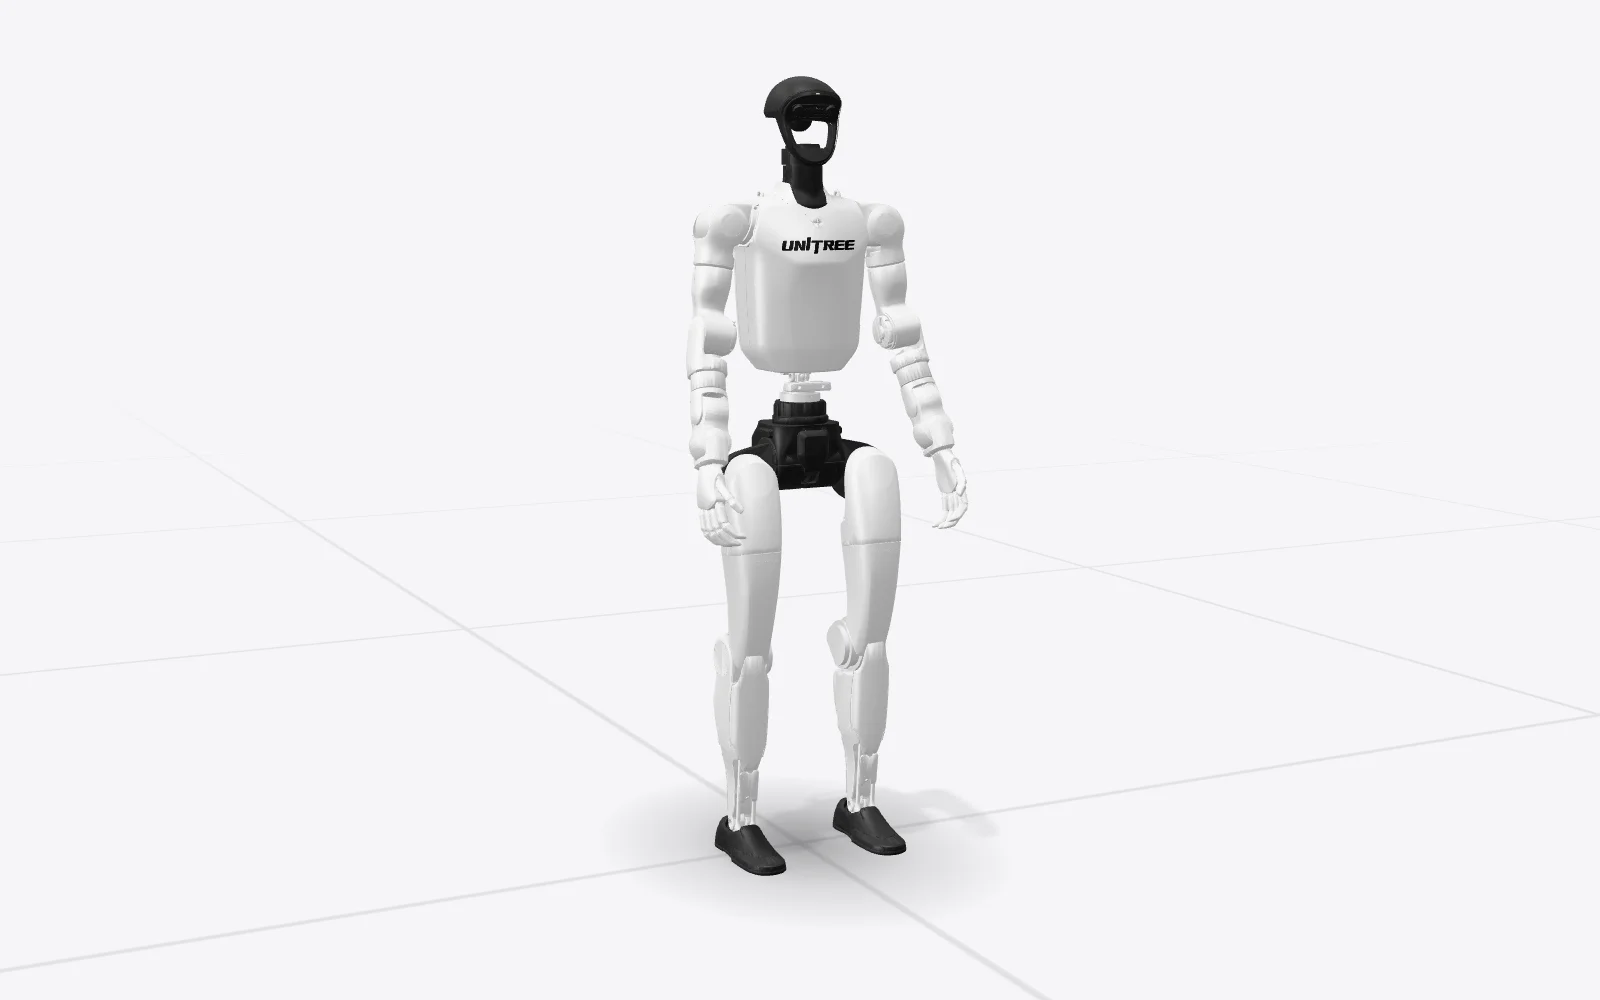
Unitree G1+
- Body
- Humanoid robot
Specifications
Mechanical Structure
- Height, width and thickness (standing)
- 1340mm x 450mm x 200mm
- Height, width and thickness (folded)
- 690mm x 450mm x 300mm
- Weight with battery
- Approx. 35kg
- Calf + thigh length
- 0.6M
- Arm span
- Approx. 0.45M
Degrees of Freedom Allocation
- Total DOF (joint motors)
- 25
- Head DOF
- 2
- Single-leg DOF
- 6
- Waist DOF
- 1
- Single-arm DOF
- 5
Joint / Actuator System
- Joint output bearing
- Industrial-grade crossed roller bearings (high precision, high load capacity)
- Joint motor
- Low-inertia, high-speed inner rotor PMSM (enhanced response & heat dissipation)
- Waist joint range
- Z±155°
- Knee joint range
- 0~165°
- Hip joint range
- P±154°、R-30~+170°、Y±158°
- Neck joint range
- Pitch -25°~36°; yaw ±110°
- Full joint hollow electrical routing
- Yes
- Joint encoder
- Dual encoders
Robot Performance Parameters
- Arm maximum load (varies greatly with arm extension posture)
- Approx. 3kg
- Cooling system
- Local air cooling
Power / Battery
- Power supply
- 13 string lithium battery
- Smart battery (quick release)
- 9000mAh
- Charger
- 54V 5A
- Battery life
- Approx. 2h
- External power supply
- Supported
Compute
- Basic computing power
- 8-Core high-performance CPU
Perception / Sensors
- Sensing sensors
- Binocular camera + chest wide-angle camera + 3D laser radar
- Binocular camera spacing
- 60mm
- Binocular camera pixels
- 2 megapixels
- Binocular camera center resolution
- ≥500LW/PH
- Binocular camera field of view
- H110° / V80° / D125°
- Wide-angle monocular camera resolution
- 1920×1080@30fps
- Wide-angle monocular camera field of view
- H117° / V67°
- Head touch sensor
- Integrated
Audio
- Microphone array
- 6 microphones (4 front, 2 rear)
- Sound source localization
- DOA
- External wireless microphone
- Supported
- Waist speakers
- 2 × 10W
Interfaces
- Wireless connectivity
- WiFi 6, Bluetooth 5.2
Accessories
- Manual controller
- Yes
Software
- Smart OTA upgrade
- Yes