Sink-Area Item Return
Return toothbrushes, toothpaste, soap, rinse cups, and hand soap to their target positions on or inside the sink cabinet.
- Domain
- Home Service Robotics
Available robots
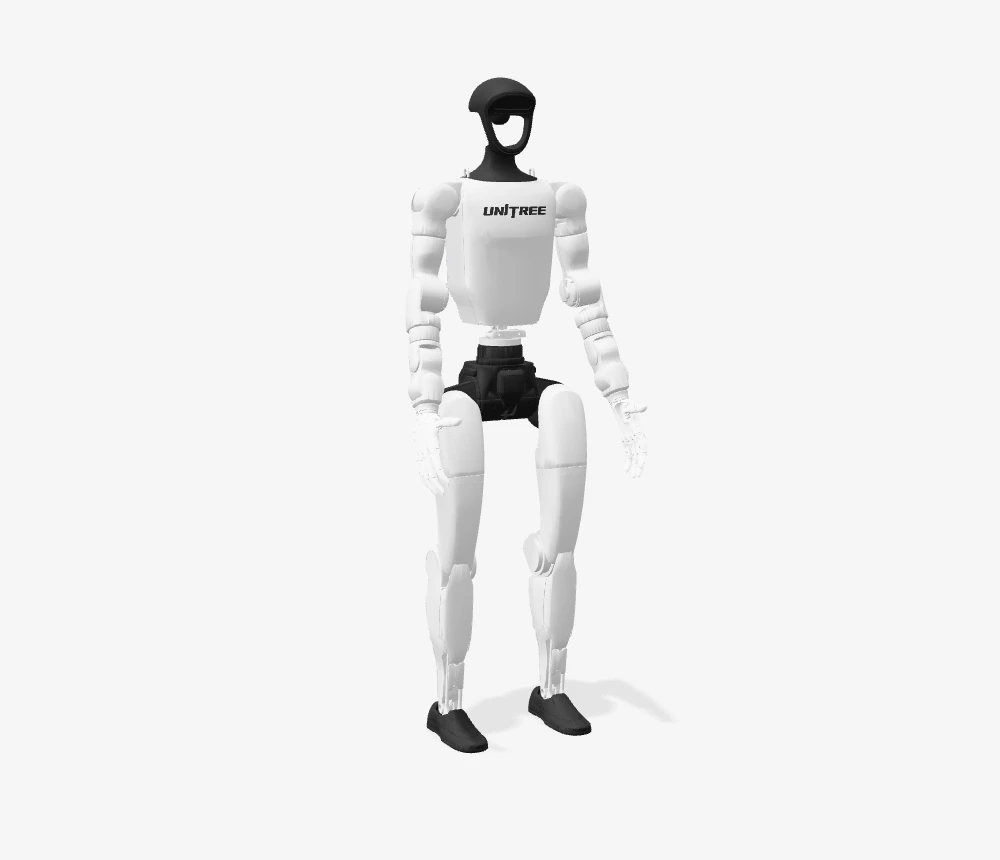
Steps
- 01Move to the right side of the sink.
- Move
- 02Pick up the soap and place it on the soap holder.
- Grasp
- Place
- Full step list available on request
Sample recordings
ExcellentNo blocking integrity failures
Checking for additional chart data…
Data integrity & timing
- Completeness100.0% of expected messages — no dropped data100%pass
- Timestamp Alignmentcameras & joints synced within ±5 ms4.78 mspass
- Signal Validity0 out-of-limit joints, 0 invalid samples0% invalidpass
- Longest stream stopno stream stop exceeded 3 s (longest 1.622 s)1.622 spass
- Stalled channelsno channel stalled longer than 3 s0pass
Image quality
- Image Qualityall sampled frames sharp, well-exposed100%pass
- Frame decodingall camera frames decoded0pass
- Image brightnessmean brightness 142.2 on a 0-255 scale142.22Measured
- Image contrastRMS contrast 38.338.3Measured
- Backlit framesno backlit frames detected on the scene camera0%pass
- Motion blurmotion blur affected 8.5 s of the 211 s episode8.5 sMeasured
Motion & control
- Motion Smoothnesssmooth, human-grade trajectories-2.52 SPARCpass
- Tracking Errorrobot followed intent within 0.043 rad (worst joint 0.494)0.043 radpass
- Left-arm trackingRMSE 0.136 rad, p95 0.305 rad0.136 radMeasured
- Right-arm trackingRMSE 0.144 rad, p95 0.313 rad0.144 radMeasured
- Active motionarms in motion 88.1% of the episode88.1%Measured
- Operator pauses2 operator pauses ≥1 s, totalling 2.3 s2Measured
Gripper behavior
- Gripper Chatterdecisive grasps, 99% idle hands4.83 transitions/minpass
- Left gripperactuated — 9 open/close cyclesyesMeasured
- Right gripperactuated — 8 open/close cyclesyesMeasured