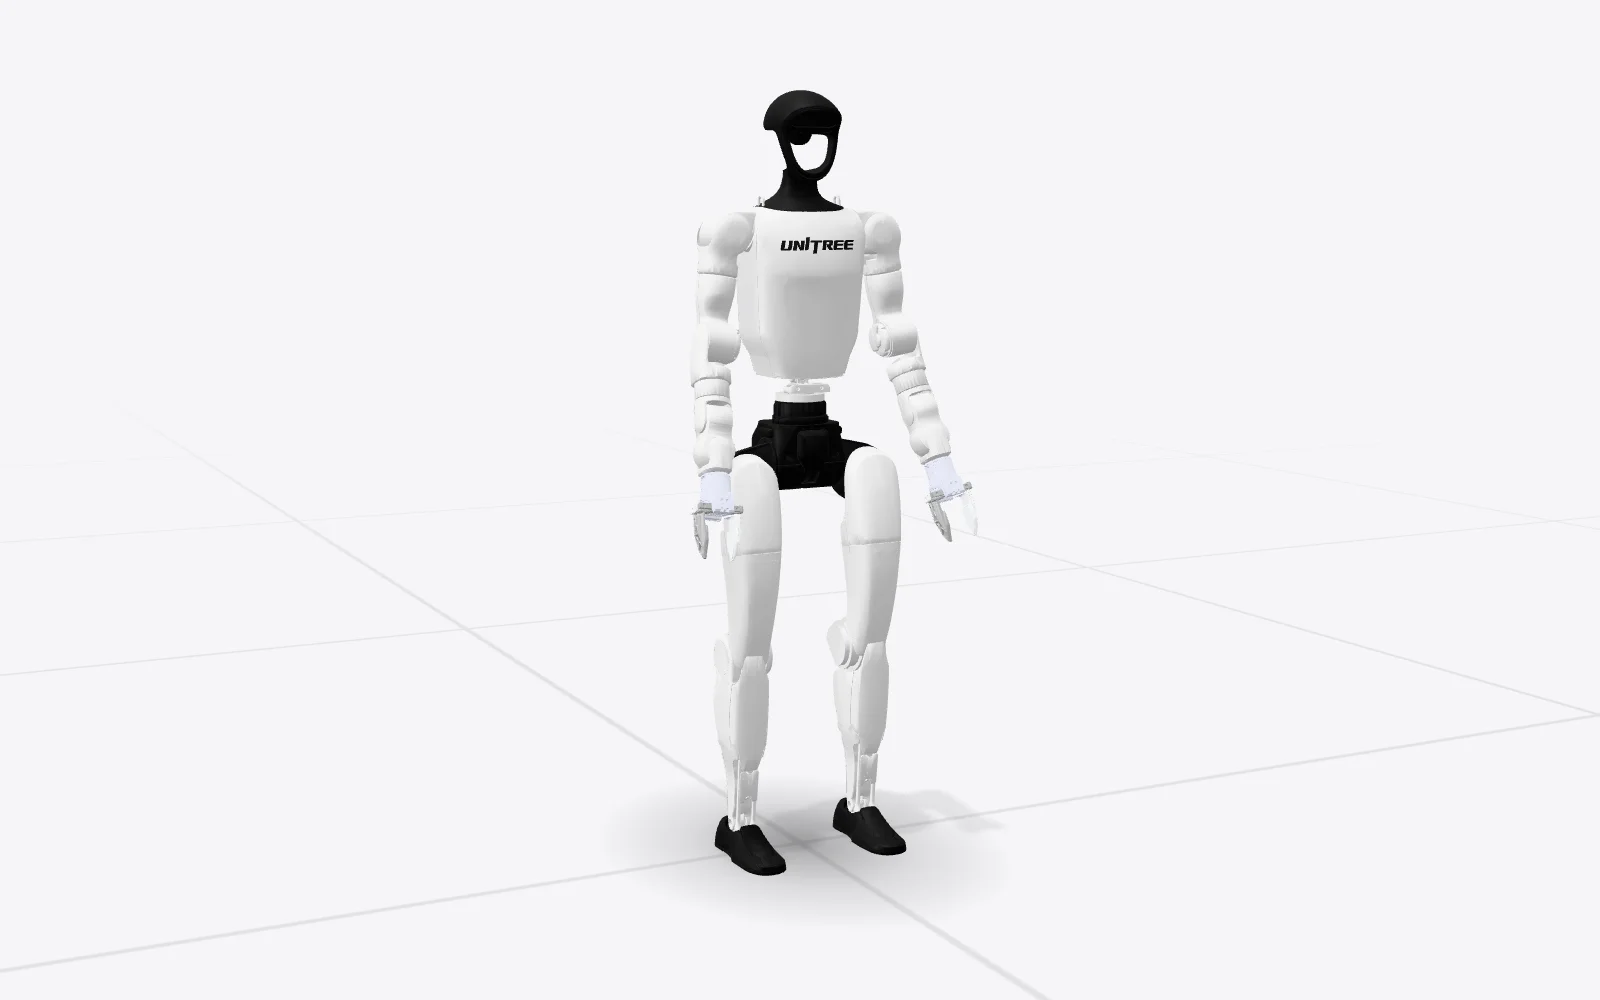
Unitree G1
- Body
- Humanoid robot
- End effector
- Gripper
- Cameras
- Monocular 720pStereo 720p
- Configurations
- 2
- Tasks
- 29
Specifications
Mechanical Structure
- Height, width, and thickness (standing)
- 1270×450×200 mm
- Height, width, and thickness (folded)
- 690×450×300 mm
- Weight with battery
- Approx. 35 kg
- Lower leg + thigh length
- 0.6 m
- Arm span
- Approx. 0.45 m
Degrees of Freedom Allocation (excluding dexterous hand)
- Total DOF
- 29 DOF (excluding dexterous hand)
- Single-leg DOF
- 6 DOF
- Single-arm DOF
- 7 DOF
- Waist DOF
- 3 DOF
Robot Performance Parameters
- Knee joint maximum torque
- 120 N·m
- Arm maximum payload
- 3 kg
- Large joint motion range
- Waist Z-axis joint: +/-155 deg; knee joint: 0-165 deg; hip joint: P +/-154 deg, R -30 to +170 deg, Y +/-158 deg
- Hollow internal cable routing for all joints
- Yes
- Joint encoder
- Dual encoders
- Cooling system
- Localized air cooling
Compute / Connectivity / Audio
- Power supply method
- 13-series battery
- Base computing power
- 8-core high-performance CPU
- Dock computing power
- Built-in 100 TOPS compute, supports secondary development, includes AI algorithms and technical support
- Wireless communication
- Supports WiFi 6 and Bluetooth 5.2
- Audio
- Standard stereo speakers and microphone array
Battery / Maintenance / Development
- Battery life
- Approx. 2 h (standard 1 battery)
- Smart OTA upgrade
- Supported
- Secondary development
- Supports high-level and low-level secondary development, with technical support, development manuals, and ecosystem support
- Warranty period
- 18 months
- Body accessories
- 1 charger, 1 handheld remote controller, 1 smart battery (quick-release)
Teleoperation / Data Collection
- Whole-body teleoperation motion-control algorithm
- Supported; manual teleoperation is available through a VR teleoperation kit
- Data acquisition platform access
- Supports connection to the data acquisition platform for robot teleoperation data collection
Sensor System
- Head HD binocular camera FOV
- H:115°, V:80°, D:125°
- Head HD binocular camera resolution
- 3840×1200
Gripper
- Compatible model
- Mainly used for G1 and G1-D
- Dimensions
- 143 mm × 78 mm × 67 mm
- Weight
- 550 g
- Stroke
- 90 mm
- Grip force (adjustable)
- 5~120 N
- Speed (adjustable)
- 50~375 mm/s
- Position resolution (fingertip)
- 0.1 mm
- Grasping load (adaptive)
- 20 kg
- Grasping load (friction)
- 5 kg
- Minimum full-stroke closing time
- 0.24 s
- Finger length
- 80 mm
- Communication protocol
- High-speed RS-485
- Communication baud rate
- 6 Mbps
- Communication control frequency
- 1000 Hz
- Operating voltage
- 24 V-64 V (24/48 VDC recommended)
- Static current
- 0.03 A
- Peak phase current
- 3.5 A
- Motor peak torque
- 5 N·m
- Maximum motor speed
- 27 rad/s (with 64 V power supply)
- Recommended operating environment
- -20℃ ~ 60℃
- Motor reduction ratio
- 01:25:00
- Motor encoder resolution
- 15 bit
- Motor encoder type
- Absolute encoder
- Motor status feedback
- Angle, angular velocity, torque, temperature
- Motor control command
- Angle, angular velocity, torque, stiffness, damping
- Built-in RGB camera FOV
- H:130°, V:60°, D:160°
- Built-in RGB camera resolution
- 1920×1080
- Secondary development
- Supports secondary development and provides robot development interfaces