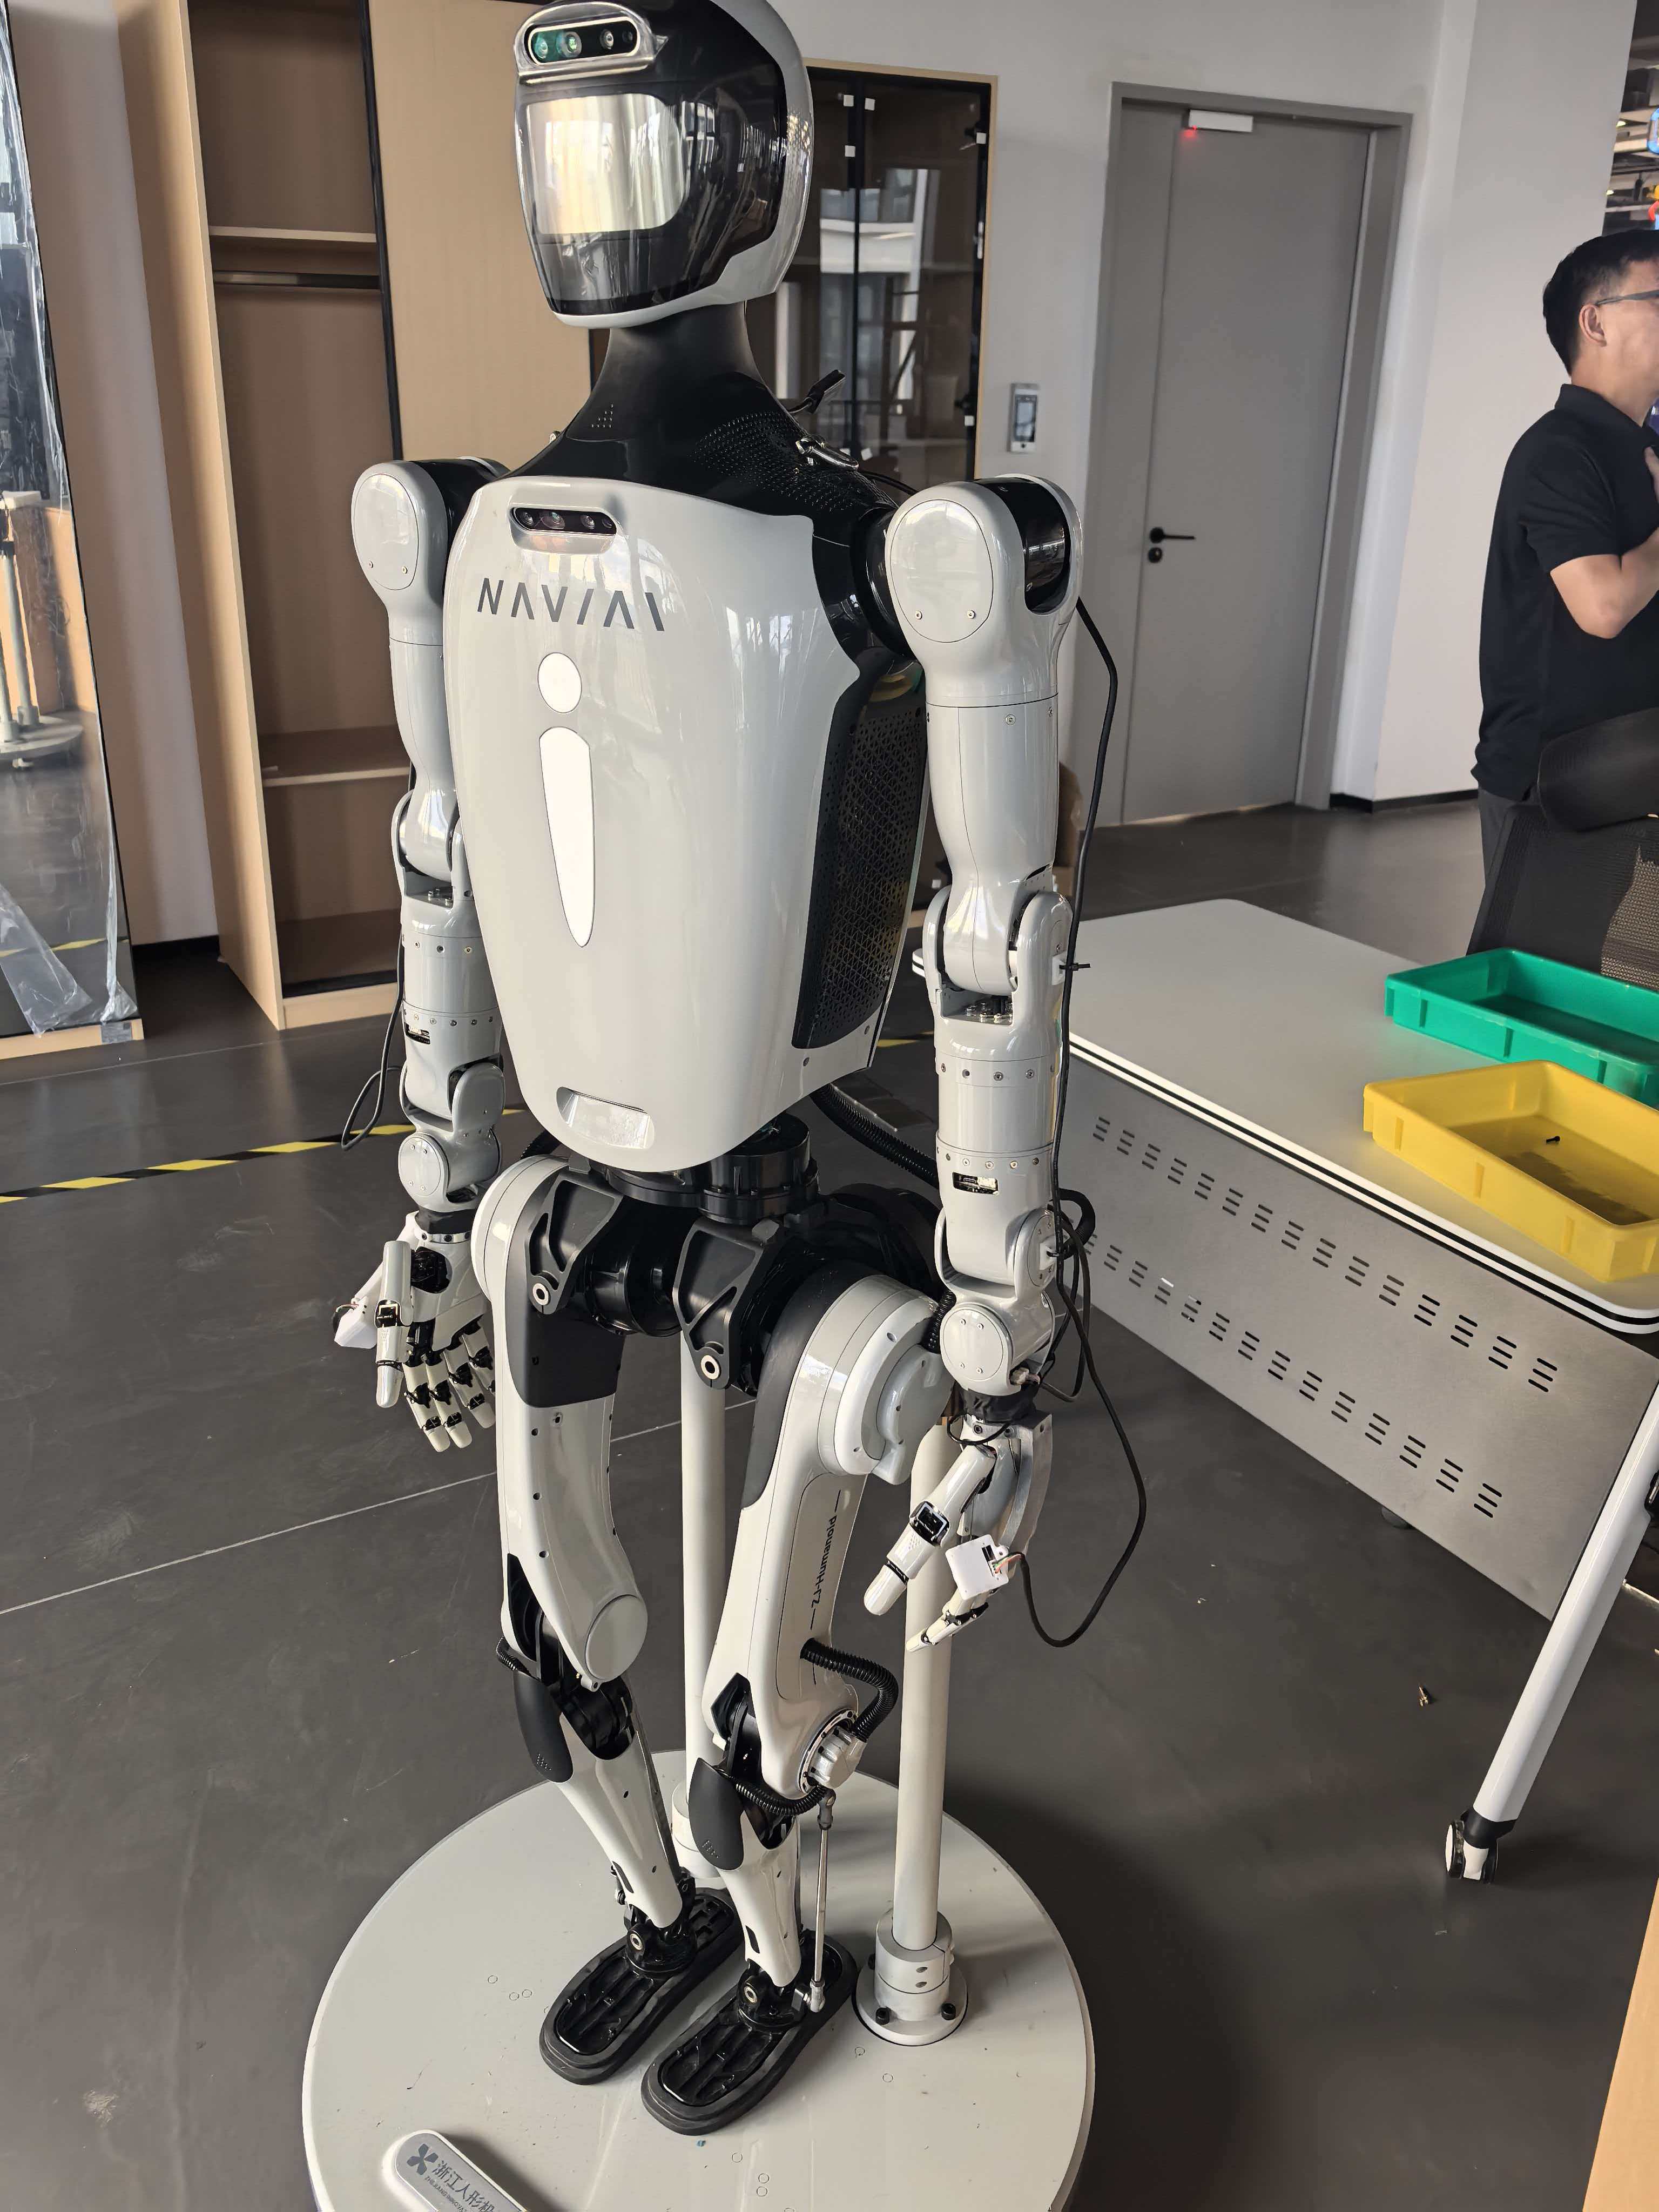
ZJ-Humanoid I2
- Body
- Humanoid robot
Specifications
General
- Model
- Zhejiang Humanoid I2
- Data Collection / Teaching Mode
- Exoskeleton-based teleoperation
- Configuration
- Full biped humanoid + dual arms + dexterous hands
- Compute Unit
- NVIDIA Jetson Orin
- Battery Life
- Approx. 1.5 hours
- Communication
- Wi-Fi, Bluetooth
- Software Framework
- ROS Noetic
DOF
- Total DOF
- 41 DOF
- Head
- 2 DOF
- Waist
- 1 DOF
- Arms
- 7 DOF × 2
- Hands
- 6 DOF × 2
- Legs
- 3 DOF × 2
End Effector
- Type
- Five-finger dexterous hands
- Fingertip Force
- 10 N
- Joint Speed
- 150°/s
Vision (Head)
- Camera Type
- RGB-D camera
- Resolution
- 1280 × 720 @ 30 Hz
- RGB FOV
- 69° × 42° (H × V)
- Depth FOV
- 87° × 58° (H × V)
- Working Range
- 0.3 – 3.0 m
- Depth Accuracy
- < 2% @ 1 m
Force Feedback
- Whole-Body Force Control
- Supported
Force Sensing
- 6-Axis Force/Torque Sensors
- 2 (left & right wrists)
- Sensor Range
- 1000 N / 13.5 Nm
Tactile Sensing
- Fingertip Tactile Sensors (Optional)
- Single-point fingertip sensors
Teleoperation
- Teleoperation Device
- Exoskeleton
Data Interface
- Middleware / API
- ROS 1 / SDK
Data Output
- Data Types
- Joint states, camera images, end-effector poses