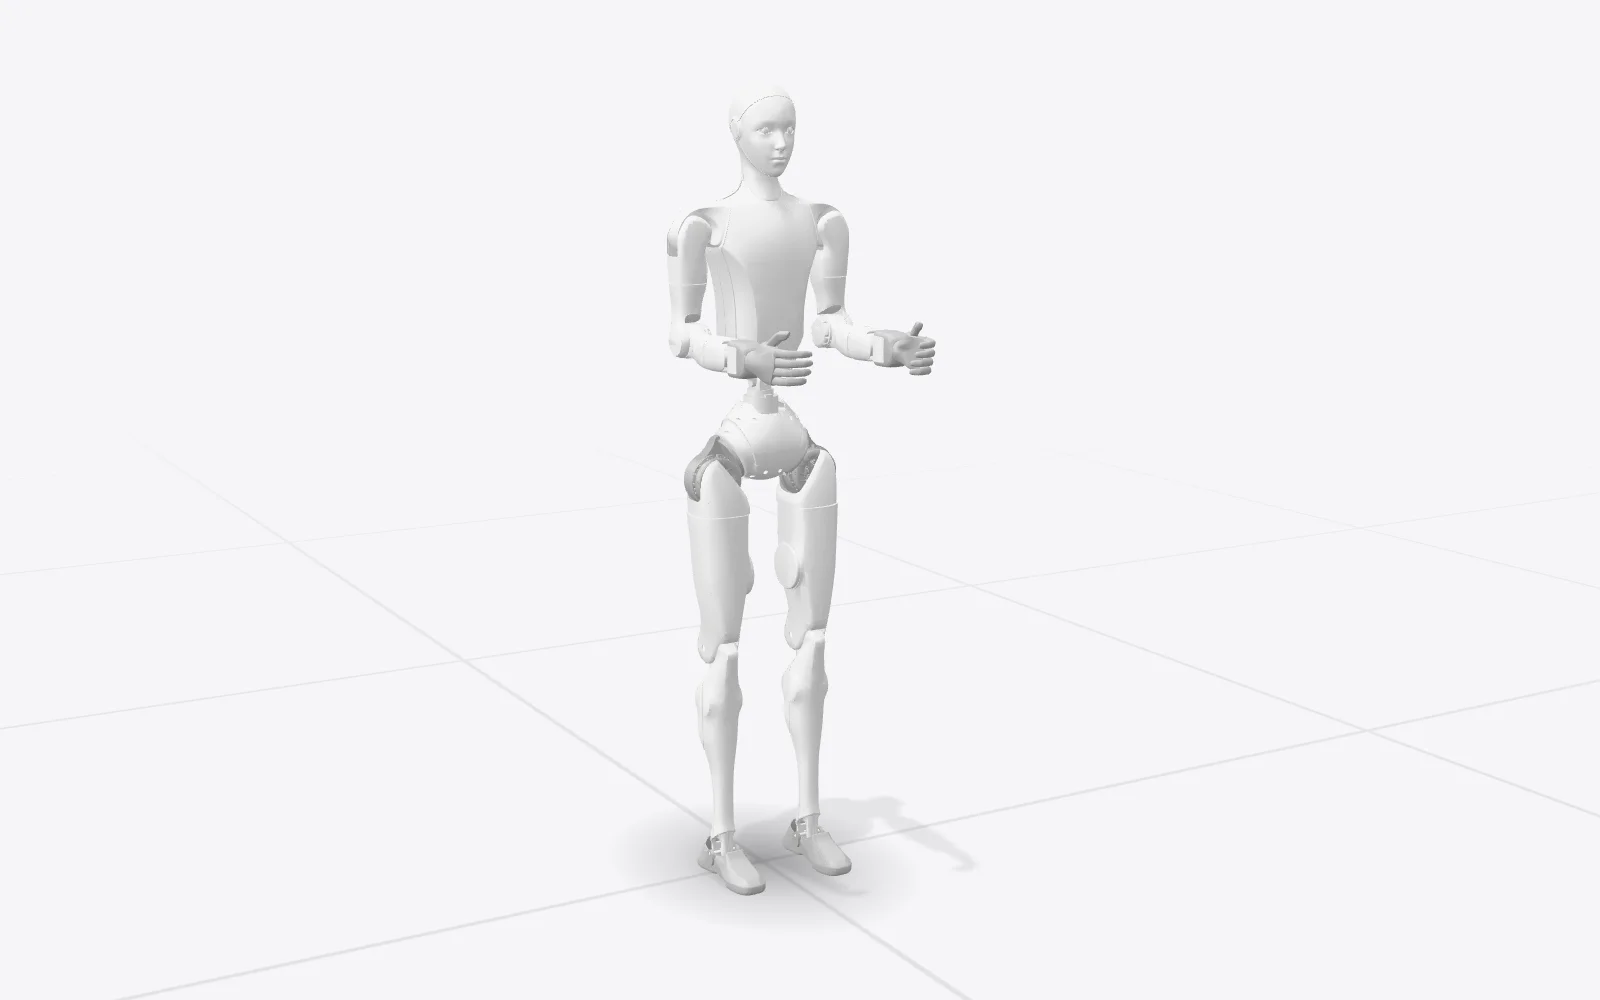
Unitree H2
- Body
- Humanoid robot
Specifications
Mechanical Structure
- Height, width, and thickness (standing)
- 1820×456×218 mm
- Weight with battery
- Approx. 70 kg
- Lower leg + thigh length
- 1045 mm
- Forearm + upper arm length
- 690 mm
- Body materials
- Aerospace aluminum + titanium alloy + high-strength engineering plastics
- Bionic head and face
- Yes
Degrees of Freedom Allocation
- Total DOF (joint motors)
- 31 DOF
- Single-leg DOF
- 6 DOF
- Single-arm DOF
- 7 DOF
- Waist DOF
- 3 DOF
- Head degrees of freedom
- 2 DOF
- Dexterous hand
- Multiple model options
Joint / Actuator System
- Joint output bearing
- Industrial-grade crossed roller bearing (high precision, high load capacity)
- Joint motor
- Low-inertia high-speed inner-rotor permanent-magnet synchronous motor (better response speed and heat dissipation)
- Maximum arm joint peak torque
- 120 N·m
- Maximum leg joint peak torque
- 360 N·m
Robot Performance Parameters
- Arm maximum payload
- Peak: approx. 15 kg; rated: approx. 7 kg
- Cooling system
- Air cooling
Power System
- Power supply method
- High-quality low-internal-resistance lithium battery
- Battery capacity
- 15 Ah(0.972 kWh)
- Battery voltage
- Maximum voltage 75.6 V
- Battery life
- Approx. 3 h
Compute / Sensors / Connectivity
- Base computing power
- PC1: Intel Core i5 (platform functions); PC2: Intel Core i7 (user development)
- Perception sensors
- Wide-FOV human-like binocular camera
- Voice interaction
- Array microphone + high-power speaker voice interaction
- Wireless communication
- WiFi 6, Bluetooth 5.2: Yes
- Expansion card slot
- PC3 and PC4 slots are empty by default; optional high-compute boards can be added, up to 2 boards (similar to B2 slot format)
Delivery / Service
- Body accessories
- 1 charger, 1 smart battery (quick-release), 1 handheld remote controller
- Smart OTA upgrade
- Supported
- Secondary development
- Supported
- Warranty period
- 12 months
- Protective bracket
- Protective bracket included by default
Dexterous Hand (planned compatibility)
- Brand
- Revo 2 Tactile (QiangNao)
- Compatibility status
- Adapted five-finger dexterous hand: QiangNao bionic dexterous hand Revo 2 tactile version (with RGB camera)
- Degrees of freedom
- 6
- Number of joints
- 11
- Weight
- 383 g
- Whole-hand grip force
- 50 N
- Single-finger pinch force
- 15 N
- Repeatability
- 0.1°
- Height
- 160 mm (middle fingertip to palm base)
- RGB camera
- FOV 160°
- Tactile sensing
- Pressure, friction, direction, proximity