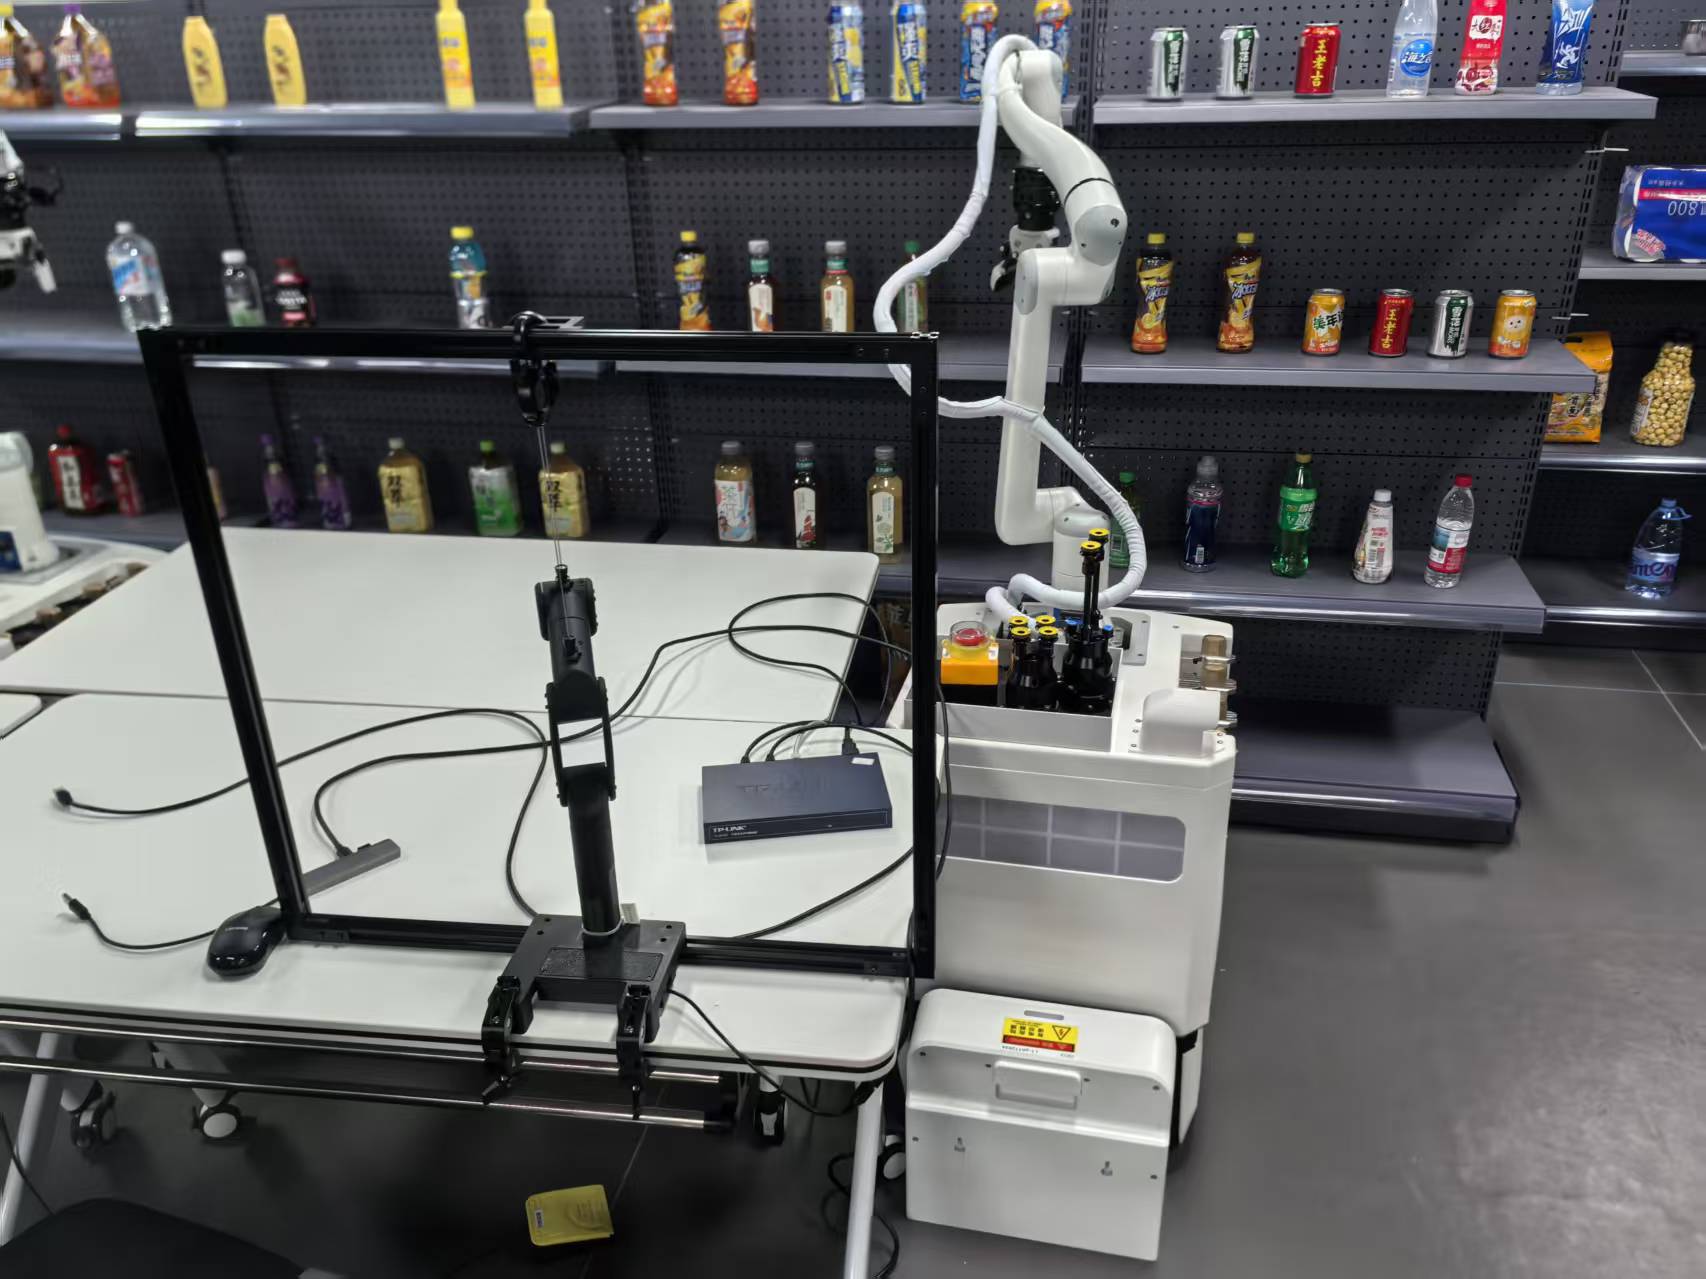
Neomatrix L1
- Body
- Robot platform
- End effector
- Adaptive two-finger gripper
- Cameras
- Arm-mounted dual RGB-D cameras
- Configurations
- 1
- Tasks
- 8
Specifications
General
- Model
- L1-ph (Single-Arm Standard Lift Platform – Pharmaceutical Application)
- Data Collection Mode
- Desktop-level mobile manipulation platform
- Configuration
- Mobile base + lifting column + robotic arm + end tools
- Dimensions (L × W × H)
- 550 × 480 × 1300 mm
- Weight
- 130 kg
- Workspace
- Reach height: 0–2 m; Reach depth: 400–600 mm
- Compute Unit (Optional)
- NVIDIA Jetson AGX Orin 64GB + 1TB SSD
- Battery Life
- 6.5 h
- Charging Time
- 3–3.5 h
- Charging Current
- < 10 A
- Communication
- Gigabit Ethernet, Wi-Fi (2.4 GHz & 5 GHz)
DOF
- Total DOF
- 10 DOF
- Robotic Arm
- 6 DOF
- End Effector
- 1 DOF
- Mobile Base
- 2 DOF
- Lifting Mechanism
- 1 DOF
Robotic Arm
- DOF
- 6 DOF
- Arm Reach
- 916 mm
- Payload
- 3 kg
- Force/Torque Sensor Range
- 200 N / 7 Nm
- Force/Torque Accuracy
- < 0.1% FS
End Effector
- Type
- Gripper / suction cup (quick-change supported)
- Standard Configuration
- Adaptive two-finger gripper
- DOF
- 1 DOF
- Maximum Stroke
- 120 mm
- Maximum Gripping Force
- 30 N
- Payload
- 1.5 kg
End Effector (Optional)
- Suction Type
- Single / dual suction cups
- Max Vacuum
- −90 kPa
- Max Flow Rate
- 50 LPM
- Max Suction Payload
- 3 kg
Vision (Arm-mounted)
- RGB-D Camera
- 1 set
- Camera Type
- Dual RGB-D camera
- RGB FOV
- 86° × 55° (H × V)
- Depth FOV
- 90° × 65° (H × V)
- Working Range
- 0.26–3 m
Lifting Mechanism
- Stroke
- 460 mm
- Speed
- 100 mm/s
Mobile Base
- DOF
- 2 DOF
- Turning Radius
- 0° (in-place rotation)
- Maximum Speed
- 1.2 m/s
- Max Obstacle Height
- 20 mm
- Obstacle Clearance
- ≤ 40 mm
- Max Climbing Angle (Rated Load)
- ≤ 10°
- Rated Payload
- 50 kg
- Drive Motors
- 6.5-inch wheel motors ×2
Navigation
- Navigation Method
- LiDAR-based SLAM
Safety
- Emergency Stop
- Remote emergency stop & on-body emergency buttons
Operation
- Teleoperation
- Single-arm teleoperation for manipulation and data collection
Development
- Secondary Development
- Open interfaces for robotic arm, base, gripper, and lifting column